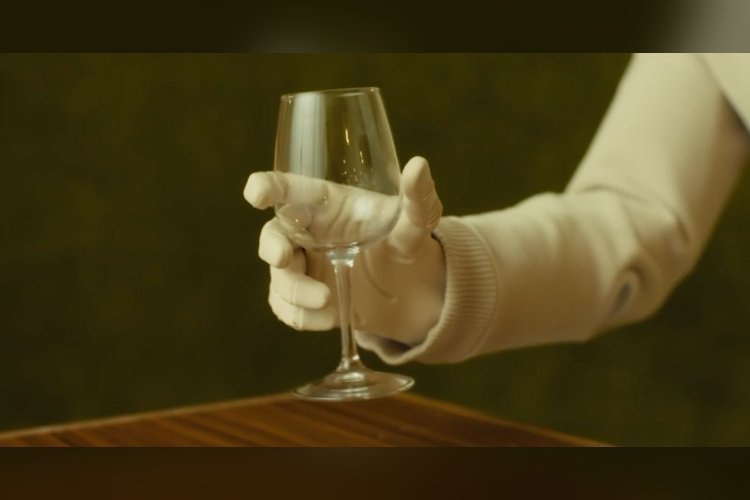
1X has unveiled new NEO humanoid hands with 25 degrees of freedom, built around tendon drives and force control. The company says hundreds have already left its production line and that it can make 10,000 this year.
The pitch is simple. If the hand is the limit on what a humanoid can do, then better hardware leaves data as the only remaining constraint on the robot’s AI models.
What is inside the hand
Of the 25 degrees of freedom, 22 are fully actuated joints in the fingers and palm, and 3 sit at the wrist. They are spread the way human anatomy spreads them, with extra weight on a thumb that can truly oppose the fingers. 1X says it picked this layout to balance human-like skill against manufacturing cost, control complexity and repairability.
The motors sit in the forearm, and tendons run through the wrist to the fingers. That keeps the hand light while still delivering strong forces, and it runs cool enough for continuous use.
1X makes the motors, electronics, sensing, tendon systems, transmissions and firmware itself.
The company frames the hand as a sensor as much as a tool. People learn about an object by pressing it, sliding a fingertip across it, hefting it and squeezing it. 1X wants NEO to learn the same way, by probing objects through contact and reading what comes back.
Why gear ratios matter
Most robot hands are command-only devices. You tell a joint where to go, and little useful information comes back. 1X blames the transmission: at the 100:1 and 200:1 gear ratios common in the field, friction absorbs contact forces before they reach the motor.
NEO’s hand uses quasi-direct-drive tendons at roughly 5:1 to 15:1. Every joint is force-controlled and backdrivable, so pushing on a finger makes it yield and reports how hard the push was. Closed-loop joints also let the hand know its own pose without a camera.
The company compares this with two-finger grippers, which leave developers with only a few basic actions. A hand that can feel opens up many more things for software to do, and it gives the AI models better information about what each grasp actually did.
Strength, precision and skin
The specs are concrete:
- Peak torque of 3.5 Nm at the thumb base and 2.6 Nm at the finger knuckle joints
- Fingertip flexion forces up to 45 N
- Wrist torque of 17.75 Nm
- Positioning accuracy of ±0.2 mm
- IP68 waterproofing with food-safe materials
The fingertips and surfaces carry high-resolution tactile sensing that measures normal force, contact location and shear. According to 1X, that lets NEO notice an object starting to slip and re-grip in real time. Vision alone struggles with small, transparent, deformable or hidden objects, which is where touch earns its place.
1X’s demonstrations include assembling LEGO, picking single screws and coins out of a wallet, installing light bulbs, using a screwdriver, zipping a jacket, pouring tea, plugging in a USB-C charger and signing. Slow-motion footage shows the fingers giving way when slapped, hit with a hammer or caught in a drawer.
The skin is designed together with the sensors beneath it and the tendons behind it, so the contact data arrives as a usable signal rather than an afterthought. 1X also says compliance is part of safety: the very low gear ratios, the tendon drive and the low inertia at the fingertips let outside impacts push the fingers back safely.
Durability claims
1X says full finger assemblies have passed millions of test cycles. It also says drive units were tested at extreme temperatures and wrist joints held up beyond 2 million cycles under heavy load. Those figures come from the company, not from independent testing.
Hands that wash themselves matter more than they sound. A robot meant to work in kitchens and homes has to survive water, cleaning and constant contact, and it has to be gentle around the people it works beside.
Why data is the real target
1X argues that a gripper limited to pick, place and push gives developers three actions to build on. A hand that senses force, shear and pose turns every grasp into labeled training data. That matters for learning-based manipulation, where robots improve by trying things and measuring the result.
CEO Bernt Børnich said the hands let NEO do “the things humans do with their hands, every day.”
The production line is the strategic part. 1X builds every unit in-house, from tendon materials and motors to the soft polymers, skin and tactile stack, and each unit gets full end-of-line testing. A hand that can’t be made in volume can’t gather data in volume, which is the company’s own argument.
What to watch next
The hands will ship on every NEO. The 10,000-unit capacity this year is the number to track, since it shows whether 1X can turn a hardware demo into a fleet that gathers data at scale. Independent tests of the durability and dexterity claims would help too.
Source: 1X Tech